Rigid-part kitting and sorting
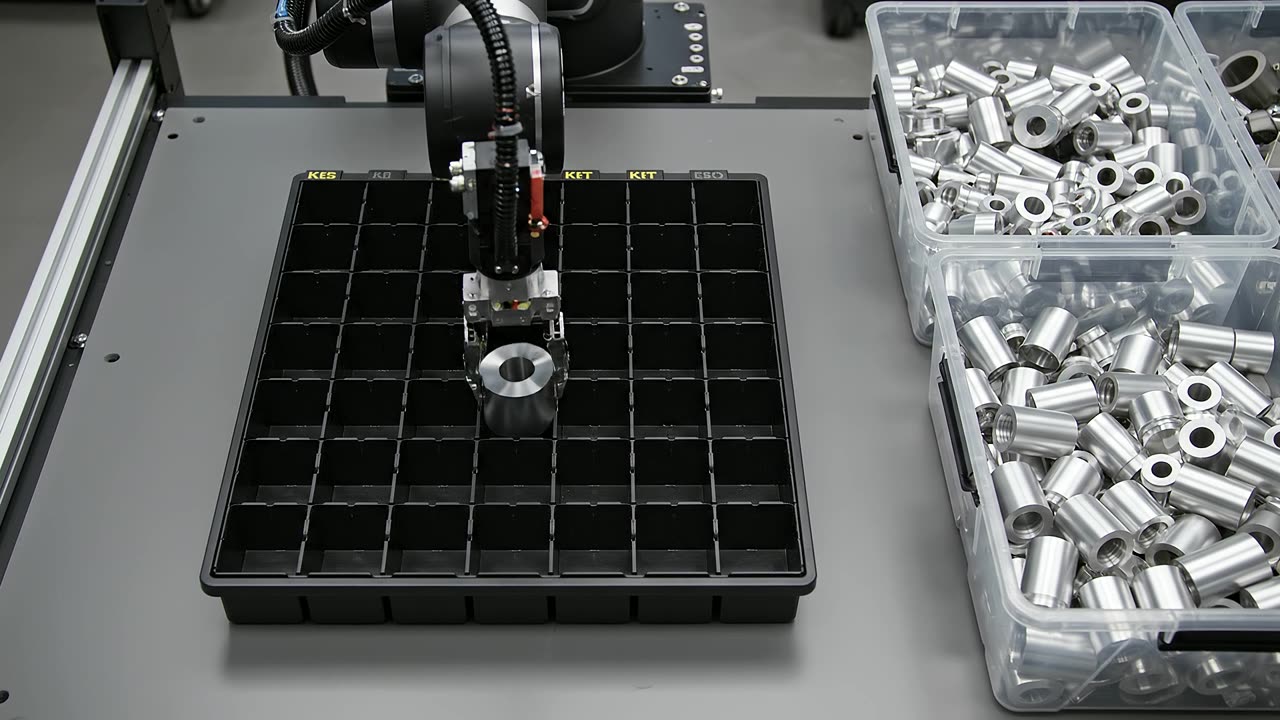
Specified · pilot scopingPick specified rigid SKUs from a mixed bin and place each into its indexed pocket in a kit tray.
3–5 owned rigid SKUs from a low-rim bin into an indexed kit tray. Single arm.
Sequence: read kit id, then inspect bin, then select part, then grasp, then orient, then place in pocket, then confirm count, then submit.
Observations
- Overhead RGB, calibrated to tray frame
- Wrist RGB
- Joint positions and gripper aperture
- Kit ID / barcode read
- Tray-occupancy state
Actions
- Leader-arm joint commands at control rate (teleop)
- Gripper open/close commands
- Phase markers: grasp, transport, place
How success is checked
- Barcode/ID plus tray-occupancy check
- Correct identity, count and pocket for every SKU
- No missing or extra part; no human intervention within the attempt
Variation and held-out cases
- SKU shape and color
- Bin pose and clutter
- Lighting
- Held-out objects and layouts reserved for evaluation
Failures and recoveries
- Wrong SKU selected
- Failed grasp
- Dropped item
- Wrong pocket
- Safe reset and corrections labeled separately from the nominal attempt
Where it is collected
- Teleoperation bench
- Dedicated collection cell
- Authorized real operation
Safety bounds. Low-rim bins, removable indexed tray, no sharp edges. Parts validated against grasp width and reach.