The world is your training set.
Verified, rights-cleared robot training data, made from real industrial work.
Verified, rights-cleared robot training data, made from real industrial work.
Request a datasetWhat Motionyard does
Motionyard supplies robot training data made from real industrial work: captured in authorized factories and dedicated cells, checked against a written specification, and licensed before anyone trains on it.
Who it is for. Teams training robot foundation models who need demonstrations of a specific skill on a specific embodiment, and the factories whose operators already perform that skill every shift.
What we collect. Authentic workplace footage, staged demonstrations, robot teleoperation trajectories and the engineering data around a task. Each is labelled and priced as what it is; they are never passed off as one another.
Where it happens. In real operations where the site and its workers have approved exactly what is recorded, and in isolated cells with owned parts, paid operators and a named supervisor. Production stays untouched.
How to start. Send a brief for one funded task gap. We scope a paid qualification batch; you review a sample against written acceptance criteria, and volume follows only once it is accepted.
Four tasks to start
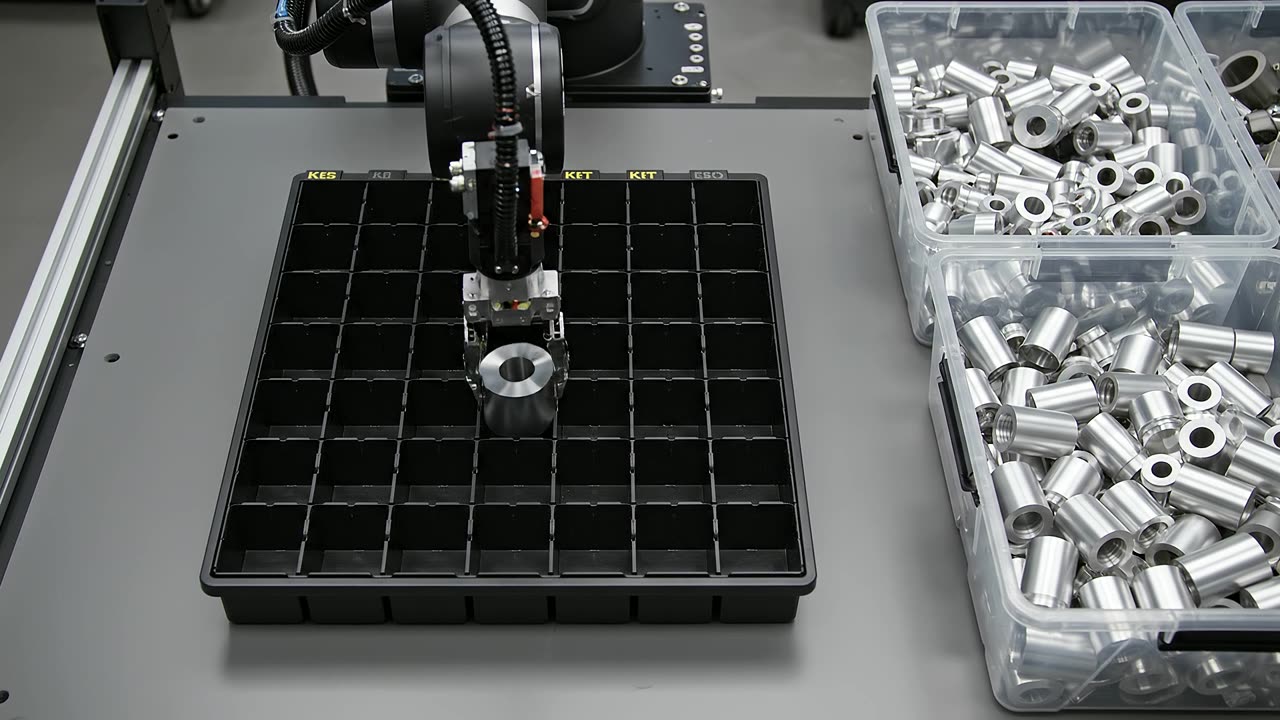
Illustration: kitting into an indexed tray Kitting and sorting
Three to five rigid parts from a mixed bin into an indexed tray, checked by ID and pocket.
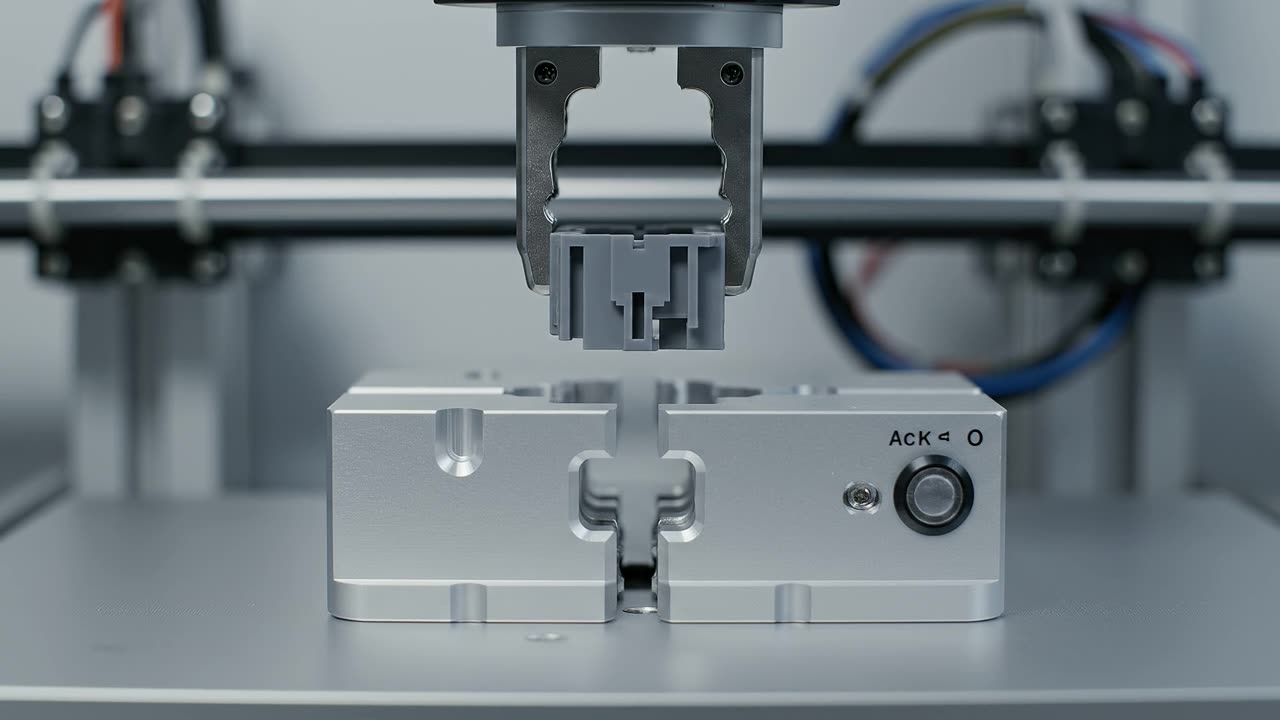
Illustration: seating a part in a keyed fixture Fixture load and inspect
Seat a part in a keyed nest, read the pass or fail signal, route it to the right tray.
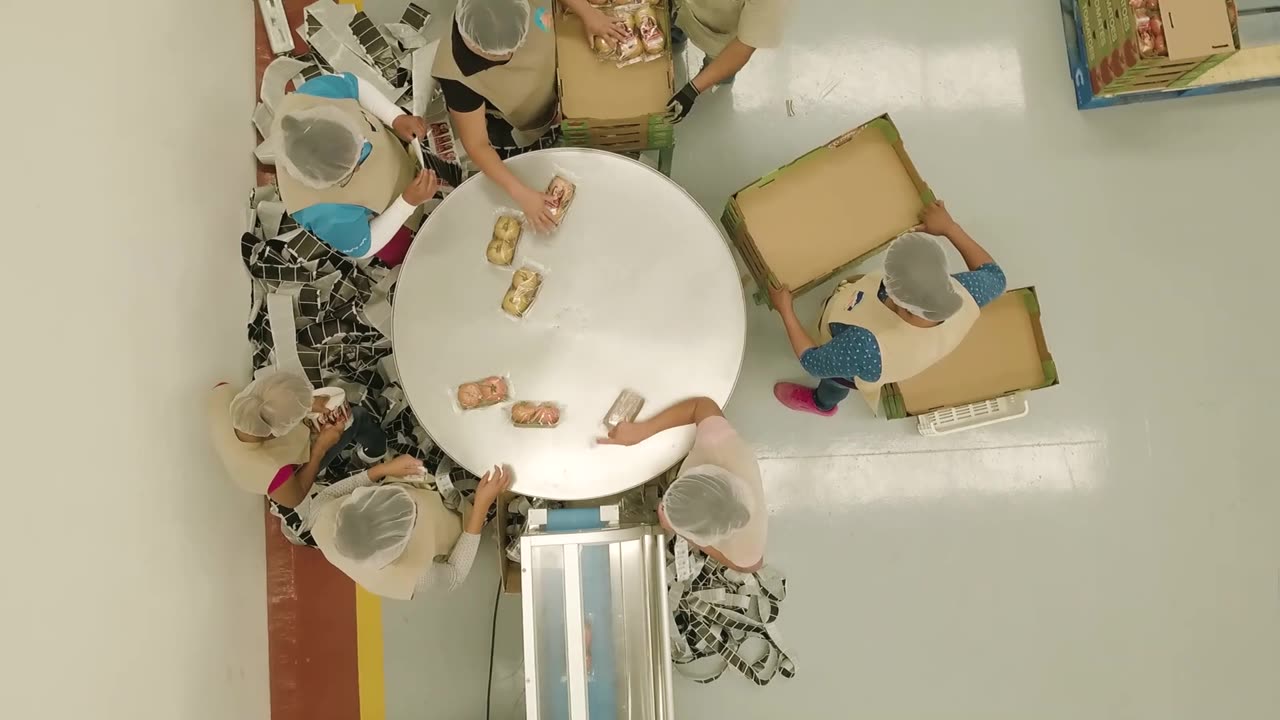
Packing cartons, from above Two-arm packout
One arm steadies the carton while the other places parts and closes the lid.
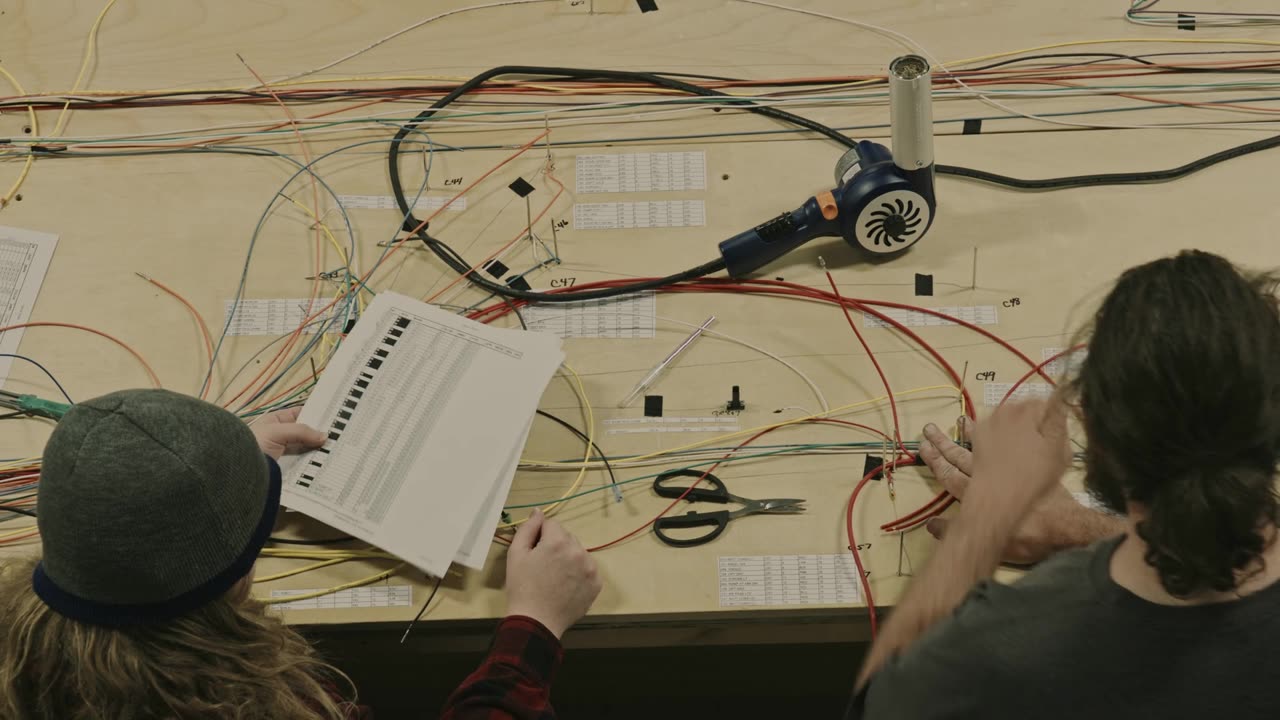
Harness routing on a formboard Harness routing
One arm keeps the slack while the other routes a cable through ordered guides.
What a robot can learn from
Physical skill is learned from what was seen, what was commanded, what the body did, and whether it worked. Most available data stops at the first.
Robot actions
Internet video: None
Raw teleop logs: Recorded, unlabelled
An accepted episode: Synchronized with every stream
A calibrated embodiment
Internet video: No
Raw teleop logs: Usually, unrecorded
An accepted episode: Hashed into every episode
Aligned timestamps
Internet video: No
Raw teleop logs: Sometimes
An accepted episode: Checked on every unit
Outcome verified
Internet video: No
Raw teleop logs: Rarely
An accepted episode: By a check the policy cannot influence
Failures and recoveries
Internet video: Not labelled
Raw teleop logs: Mixed in
An accepted episode: Labelled and kept
Interventions
Internet video: Unknown
Raw teleop logs: Often missing
An accepted episode: Flagged, never edited out
Rights for training
Internet video: Unclear
Raw teleop logs: Depends on the lab
An accepted episode: Written into the contract
Reproducible versions
Internet video: No
Raw teleop logs: Ad hoc
An accepted episode: Checksummed releases
What we deliver
You pay for accepted episodes, not hours. Each one is reviewed against the contract and either accepted or kept with a reason code. Try reviewing the sample below.
Captured
Reviewed
- Streams
- 7 of 7 present
- Clock alignment
- Within spec
- Calibration
- Matches the session
- Outcome
- Tray check passed
- Interventions
- None
- Rights
- Site and operator consent on file
Delivered
A sample record; the figures are illustrative.
From brief to next batch
Every stage leaves something you can check. When your policy is evaluated, its failures become the next specification, and targeted collection is measured against an equal-budget control.
How the platform worksBefore collection
- Task specificationSkill, embodiment, streams
- Acceptance termsReview window, codes
- Rights and site approvalIn writing
During collection
- Pilot sampleReviewed by you
- Supervised captureEvery attempt logged
- ValidationAccepted or coded
After delivery
- Versioned datasetManifest, checksums
- EvaluationFailure profile
- Next batchAgainst a control
You hold accepted dataand what to collect next
Why we are building this
The skill that runs a factory lives in operators' hands: seating a part without forcing it, keeping slack in a harness, closing a carton while the other hand holds it steady. Almost none of it is recorded in a form a robot can learn from.
We think physical AI is short of the right data more than of data. Demonstrations captured to a written specification, on a known embodiment, with the outcome checked by something the model cannot influence, and with rights that hold up.
So we sell accepted episodes, not hours. When a buyer's policy fails, the failures tell us what to collect next, and we test that choice against an equal-budget control.
Over time we want that loop to run with fewer people in it. We have not shown that yet, and we will say so plainly until we have.
We are early and choosing our first programs carefully. If your robot cannot learn a task yet, or your operators already do it well, write to us.
The Motionyard team
Helm Technology Inc.
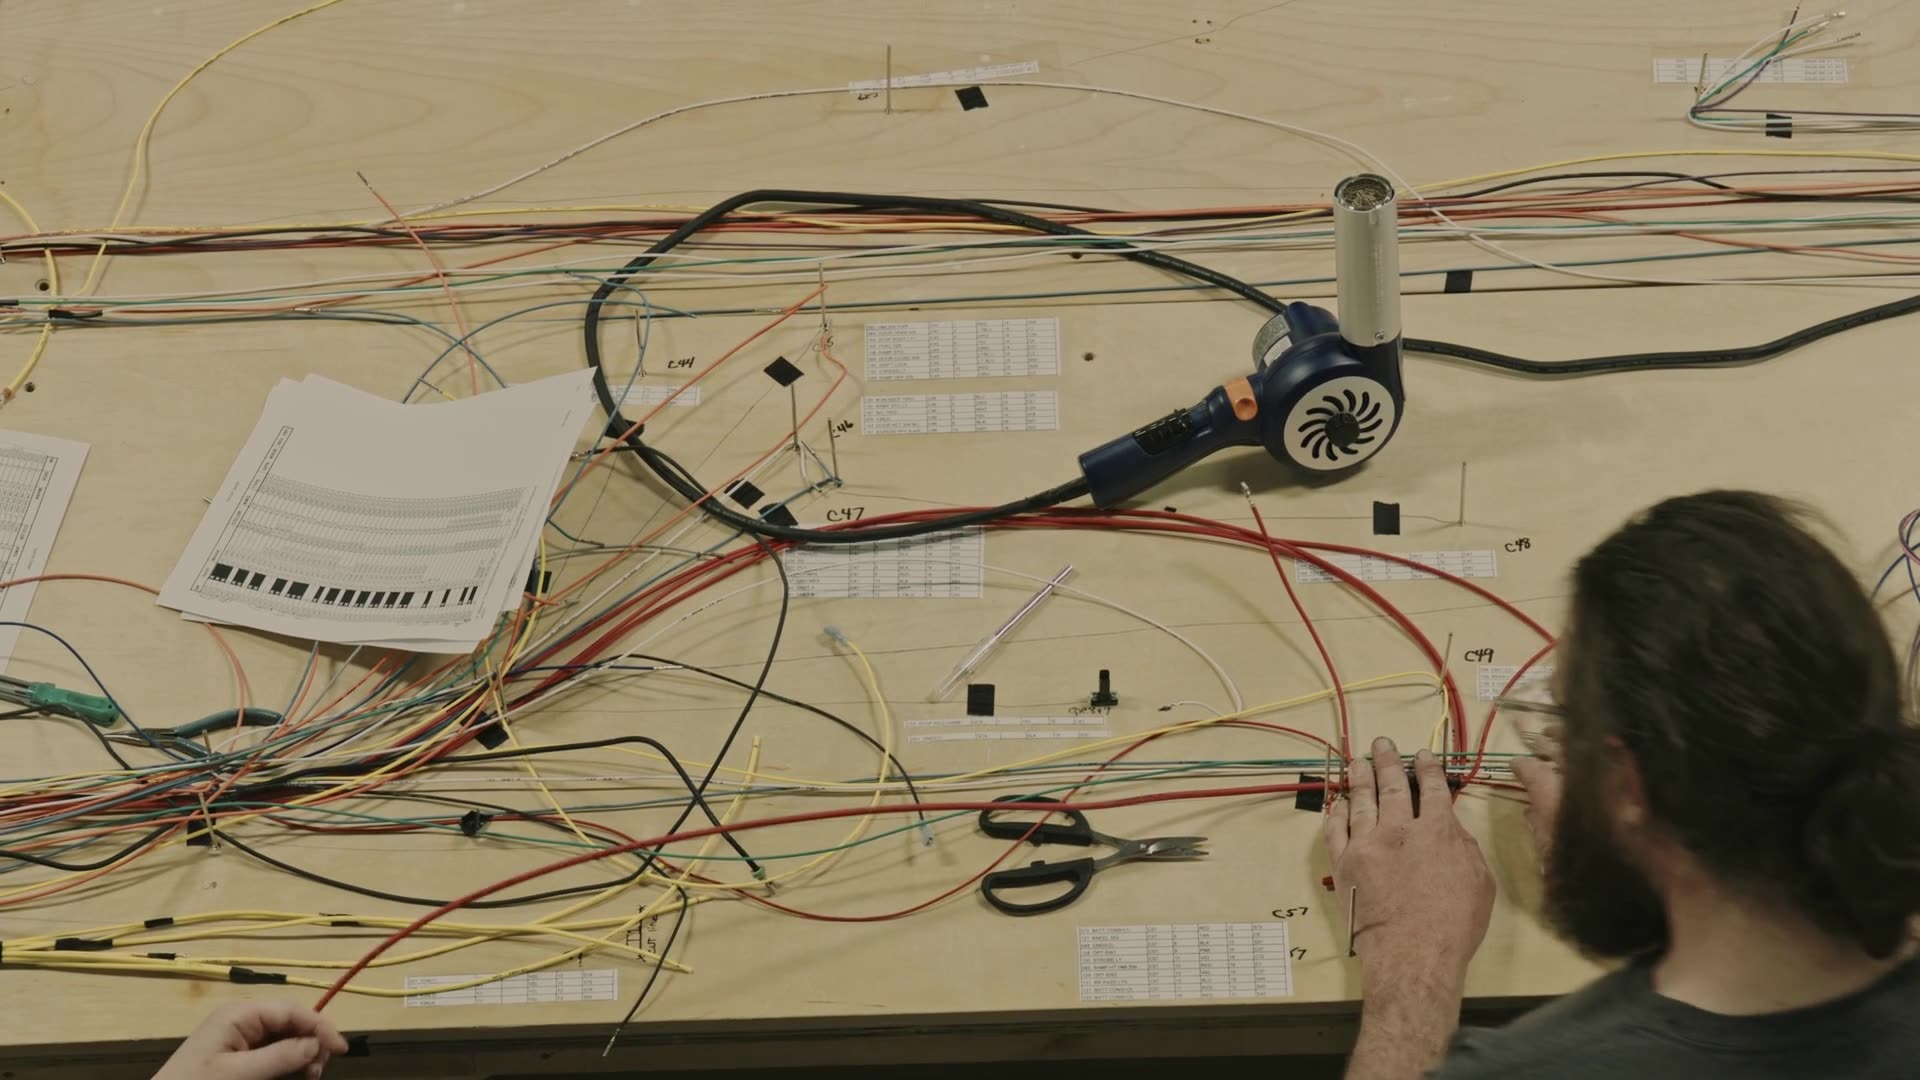
Your operators know the hard parts
Factories, contract manufacturers and operations providers earn from the specific workflows they authorize. Nothing is recorded without written approval of what is captured; customer designs stay out, and work is paid on agreed terms.
Become a data partnerDelivered in the format your stack reads, such as
- LeRobotDataset
- RLDS
- HDF5
- MCAP
- Zarr
Teach machines how the world works.
Tell us the skill your robot cannot learn yet, and we will scope the data for it.